

Postdoctoral Researcher: Academic CV, seven pages
A 7-page single-column resume from the expert-built (canva / latex) set. The median system scores 75.5 F1 on it; Qwen 3.8 27B scores best (87.0) and GLM 5.3 Flash worst (13.6). It is the fifth hardest of the 20 published resumes.
- Many entries
- Long bullet lists
- Split across pages
- Big skills list
- Custom sections
- Partial dates
First 3 of 7 pages shown.
Every system on this resume
| Model | F1 here | F1 overall | Gap |
|---|---|---|---|
| Qwen 3.8 27B | 87.0 | 83.8 | +3.2 |
| Claude Opus 4.8 | 86.2 | 85.5 | +0.7 |
| Qwen 3.8 Flash | 81.1 | 84.1 | −3.0 |
| Gemini 3.5 Flash | 80.5 | 85.5 | −4.9 |
| LlamaParse Extract Cost-Effective | 80.2 | 83.5 | −3.3 |
| Reducto Deep Extract | 79.9 | 85.6 | −5.6 |
| LlamaParse Extract Agentic Plus | 77.9 | 87.2 | −9.3 |
| GPT-5.5 | 76.6 | 83.5 | −6.9 |
| Qwen 3.5 35B | 75.5 | 77.9 | −2.4 |
| LlamaParse Extract Agentic | 75.4 | 85.5 | −10.1 |
| Extend Max Context | 73.4 | 84.7 | −11.3 |
| GPT-5.6 | 72.3 | 84.7 | −12.5 |
| Reducto Extract | 71.8 | 81.7 | −9.9 |
| Qwen 3.5 9B | 71.2 | 76.0 | −4.9 |
| Gemma 4 26B | 56.8 | 62.8 | −6.0 |
| Extend Extract | 54.2 | 81.0 | −26.8 |
| GPT-5.4 Nano | 46.0 | 61.9 | −15.9 |
| GLM 5.3 Flash | 13.6 | 59.2 | −45.6 |
Ground truth
What every system is scored against. The person is fictional. Download it (JSON), free to reuse under CC BY 4.0.
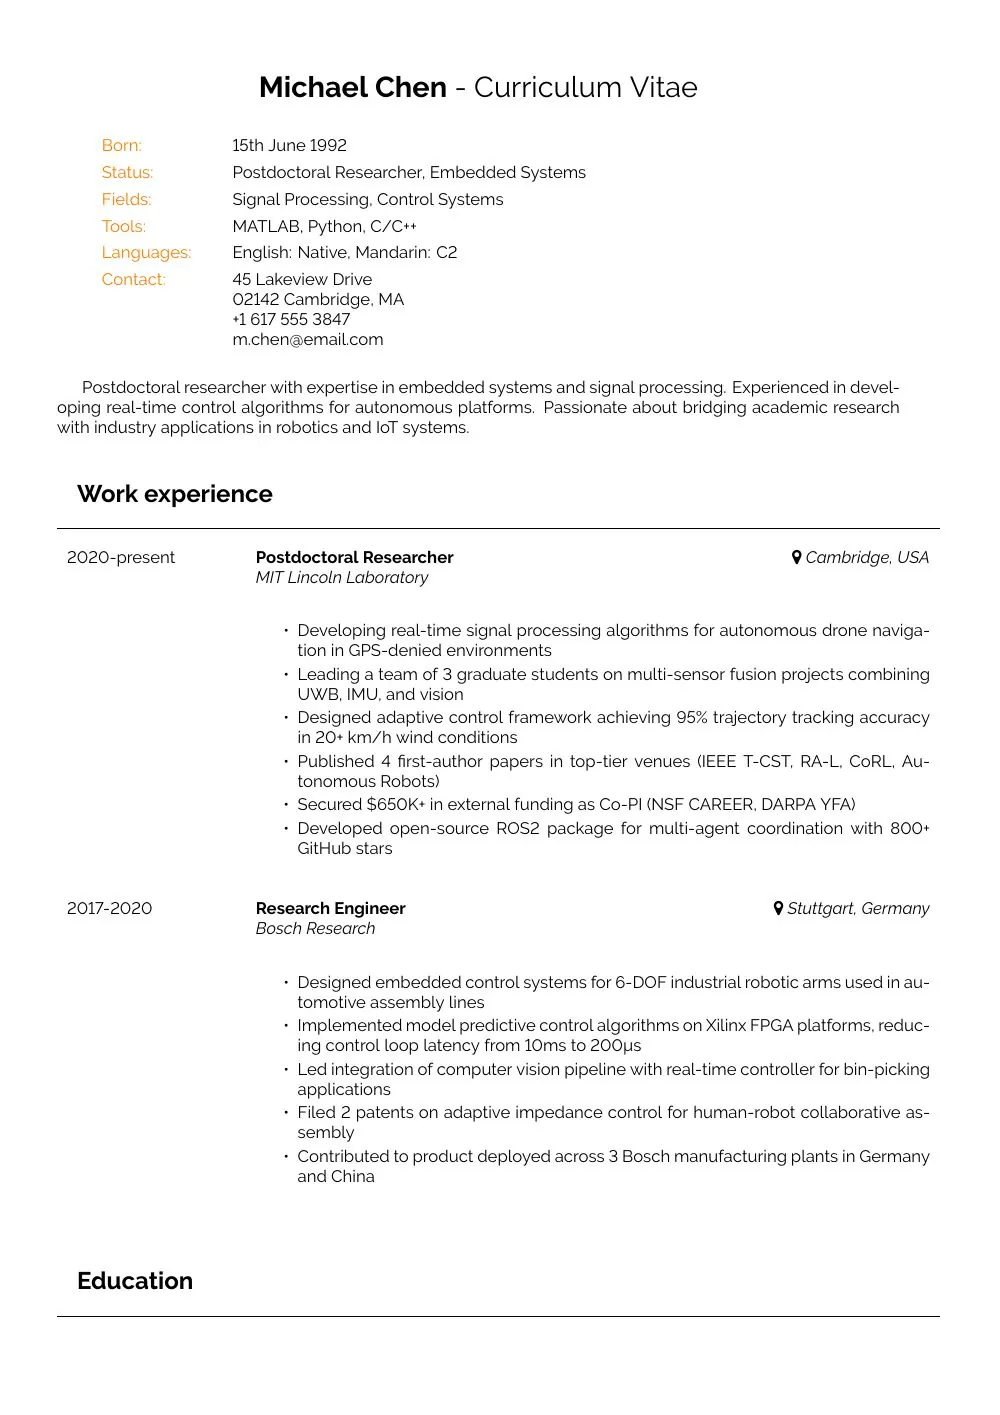
Contact
- First name
- Michael
- Last name
- Chen
- m.chen@email.com
- Phone
- +1 617 555 3847
- City
- Cambridge
- State
- MA
- Country
- USA
- Headline
- Postdoctoral Researcher, Embedded Systems
Summary
Postdoctoral researcher with expertise in embedded systems and signal processing. Experienced in developing real-time control algorithms for autonomous platforms. Passionate about bridging academic research with industry applications in robotics and IoT systems.
Experience
Postdoctoral Researcher · MIT Lincoln Laboratory
2020 – present · Cambridge, USA
- Developing real-time signal processing algorithms for autonomous drone navigation in GPS-denied environments
- Leading a team of 3 graduate students on multi-sensor fusion projects combining UWB, IMU, and vision
- Designed adaptive control framework achieving 95% trajectory tracking accuracy in 20+ km/h wind conditions
- Published 4 first-author papers in top-tier venues (IEEE T-CST, RA-L, CoRL, Autonomous Robots)
- Secured $650K+ in external funding as Co-PI (NSF CAREER, DARPA YFA)
- Developed open-source ROS2 package for multi-agent coordination with 800+ GitHub stars
Research Engineer · Bosch Research
2017 – 2020 · Stuttgart, Germany
- Designed embedded control systems for 6-DOF industrial robotic arms used in automotive assembly lines
- Implemented model predictive control algorithms on Xilinx FPGA platforms, reducing control loop latency from 10ms to 200µs
- Led integration of computer vision pipeline with real-time controller for bin-picking applications
- Filed 2 patents on adaptive impedance control for human-robot collaborative assembly
- Contributed to product deployed across 3 Bosch manufacturing plants in Germany and China
Education
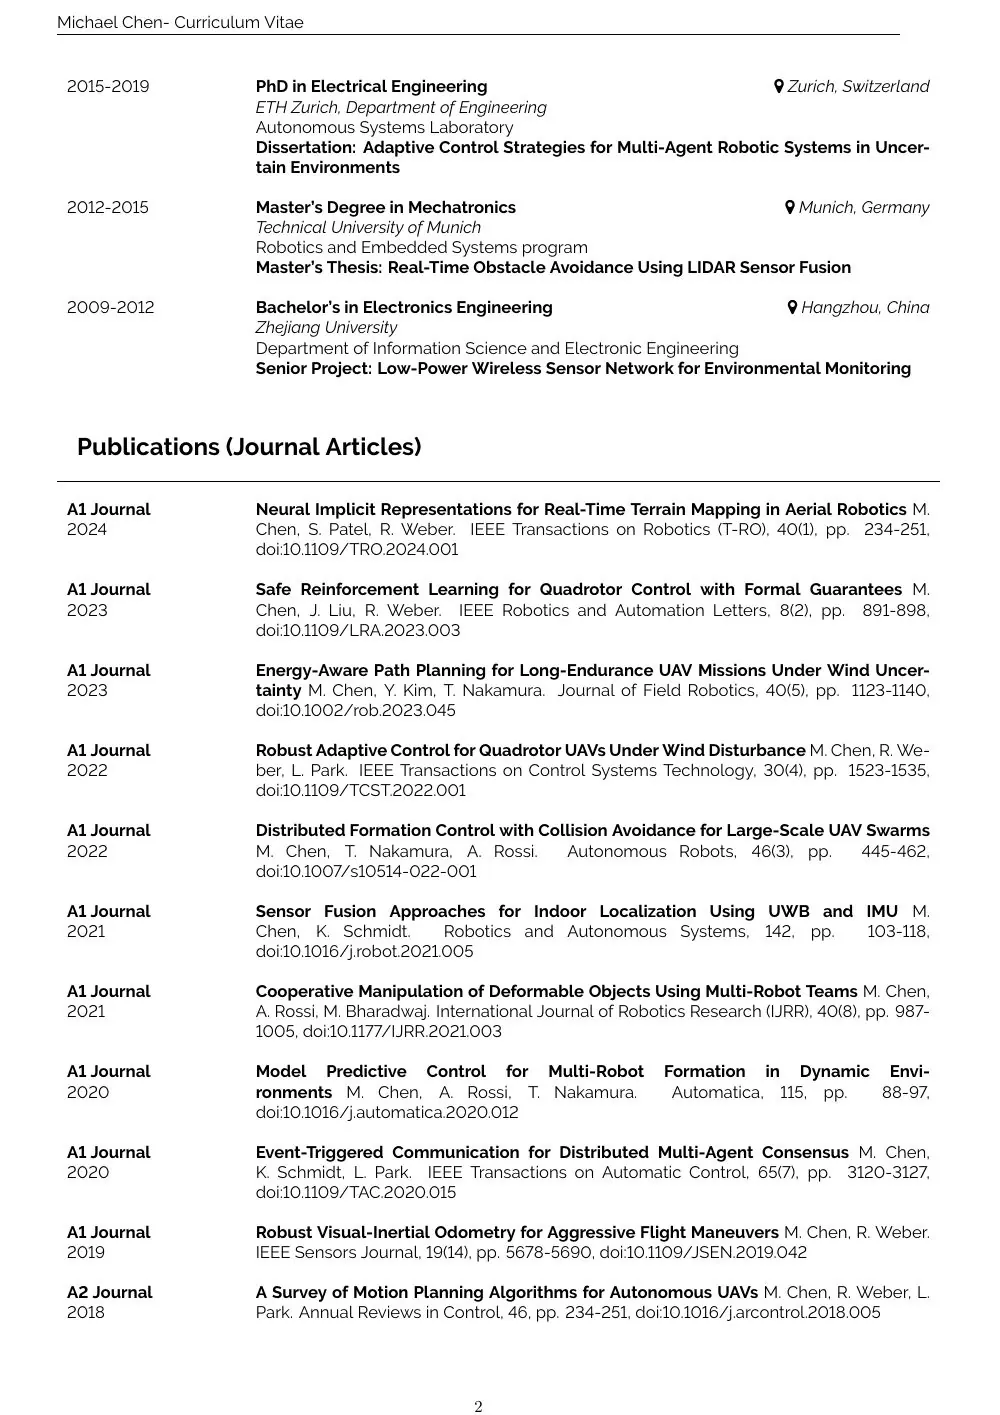
PhD · ETH Zurich, Department of Engineering
2015 – 2019 · Zurich, Switzerland · Electrical Engineering
- Autonomous Systems Laboratory
- Dissertation: Adaptive Control Strategies for Multi-Agent Robotic Systems in Uncertain Environments
Master’s Degree · Technical University of Munich
2012 – 2015 · Munich, Germany · Mechatronics
- Robotics and Embedded Systems program
- Master’s Thesis: Real-Time Obstacle Avoidance Using LIDAR Sensor Fusion
Bachelor’s · Zhejiang University
2009 – 2012 · Hangzhou, China · Electronics Engineering
- Department of Information Science and Electronic Engineering
- Senior Project: Low-Power Wireless Sensor Network for Environmental Monitoring
Skills
Programming: C/C++, C/C++: Expert, CUDA, CUDA: Intermediate, MATLAB, MATLAB: Expert, Python, Python: Expert, Rust, Rust: Intermediate, VHDL, VHDL: Intermediate
Frameworks: JAX, JAX: Intermediate, PyTorch, PyTorch: Advanced, ROS/ROS2, ROS/ROS2: Expert, TensorFlow, TensorFlow: Intermediate
Platforms: DJI SDK, Intel RealSense, NVIDIA Jetson, PX4 Autopilot, Xilinx Vivado/Vitis
Tools: Docker, Gazebo, Git, Isaac Sim, LATEX, MATLAB/Simulink, SolidWorks, Signal Processing, Control Systems
Projects
MultiAgentSim
2023
- Open-source simulation framework for multi-robot coordination research. Supports up to 500 agents in real-time. 800+ GitHub stars, used by 15+ research groups worldwide.
SafeRL-Quad
2022
- PyTorch-based safe reinforcement learning library for quadrotor control with formal barrier certificates. 450+ stars, integrated into 3 published papers by external groups.
ros2_formation_control
2020
- ROS2 package for distributed formation control of UAV swarms. Deployed on DJI and PX4 platforms. 300+ stars, 50+ forks.
Awards
IEEE Robotics and Automation Society Early Career Award · IEEE Robotics and Automation Society
2024
Best Paper Finalist, Conference on Robot Learning (CoRL) · Conference on Robot Learning (CoRL)
2023
MIT Lincoln Laboratory Technical Excellence Award · MIT Lincoln Laboratory
2022
DARPA Young Faculty Award recipient · DARPA
2021
ETH Medal for Outstanding Doctoral Thesis · ETH Zurich
2019
Best Paper Award, ICRA Workshop on Aerial Robotics · ICRA Workshop on Aerial Robotics
2019
Bosch Research Innovation Prize · Bosch Research
2018
internal, EUR 10,000
DAAD Scholarship for International Graduate Studies · DAAD
2015
· Zhejiang University
2012
top 2%
Publications
Neural Implicit Representations for Real-Time Terrain Mapping in Aerial Robotics · IEEE Transactions on Robotics (T-RO)
2024
M. Chen, S. Patel, R. Weber. IEEE Transactions on Robotics (T-RO), 40(1), pp. 234-251, doi:10.1109/TRO.2024.001
Safe Reinforcement Learning for Quadrotor Control with Formal Guarantees · IEEE Robotics and Automation Letters
2023
M. Chen, J. Liu, R. Weber. IEEE Robotics and Automation Letters, 8(2), pp. 891-898, doi:10.1109/LRA.2023.003
Energy-Aware Path Planning for Long-Endurance UAV Missions Under Wind Uncertainty · Journal of Field Robotics
2023
M. Chen, Y. Kim, T. Nakamura. Journal of Field Robotics, 40(5), pp. 1123-1140, doi:10.1002/rob.2023.045
Robust Adaptive Control for Quadrotor UAVs Under Wind Disturbance · IEEE Transactions on Control Systems Technology
2022
M. Chen, R. Weber, L. Park. IEEE Transactions on Control Systems Technology, 30(4), pp. 1523-1535, doi:10.1109/TCST.2022.001
Distributed Formation Control with Collision Avoidance for Large-Scale UAV Swarms · Autonomous Robots
2022
M. Chen, T. Nakamura, A. Rossi. Autonomous Robots, 46(3), pp. 445-462, doi:10.1007/s10514-022-001
Sensor Fusion Approaches for Indoor Localization Using UWB and IMU · Robotics and Autonomous Systems
2021
M. Chen, K. Schmidt. Robotics and Autonomous Systems, 142, pp. 103-118, doi:10.1016/j.robot.2021.005
Cooperative Manipulation of Deformable Objects Using Multi-Robot Teams · International Journal of Robotics Research (IJRR)
2021
M. Chen, A. Rossi, M. Bharadwaj. International Journal of Robotics Research (IJRR), 40(8), pp. 987- 1005, doi:10.1177/IJRR.2021.003
Model Predictive Control for Multi-Robot Formation in Dynamic Environments · Automatica
2020
M. Chen, A. Rossi, T. Nakamura. Automatica, 115, pp. 88-97, doi:10.1016/j.automatica.2020.012
Event-Triggered Communication for Distributed Multi-Agent Consensus · IEEE Transactions on Automatic Control
2020
M. Chen, K. Schmidt, L. Park. IEEE Transactions on Automatic Control, 65(7), pp. 3120-3127, doi:10.1109/TAC.2020.015
Robust Visual-Inertial Odometry for Aggressive Flight Maneuvers · IEEE Sensors Journal
2019
M. Chen, R. Weber. IEEE Sensors Journal, 19(14), pp. 5678-5690, doi:10.1109/JSEN.2019.042
A Survey of Motion Planning Algorithms for Autonomous UAVs · Annual Reviews in Control
2018
M. Chen, R. Weber, L. Park. Annual Reviews in Control, 46, pp. 234-251, doi:10.1016/j.arcontrol.2018.005
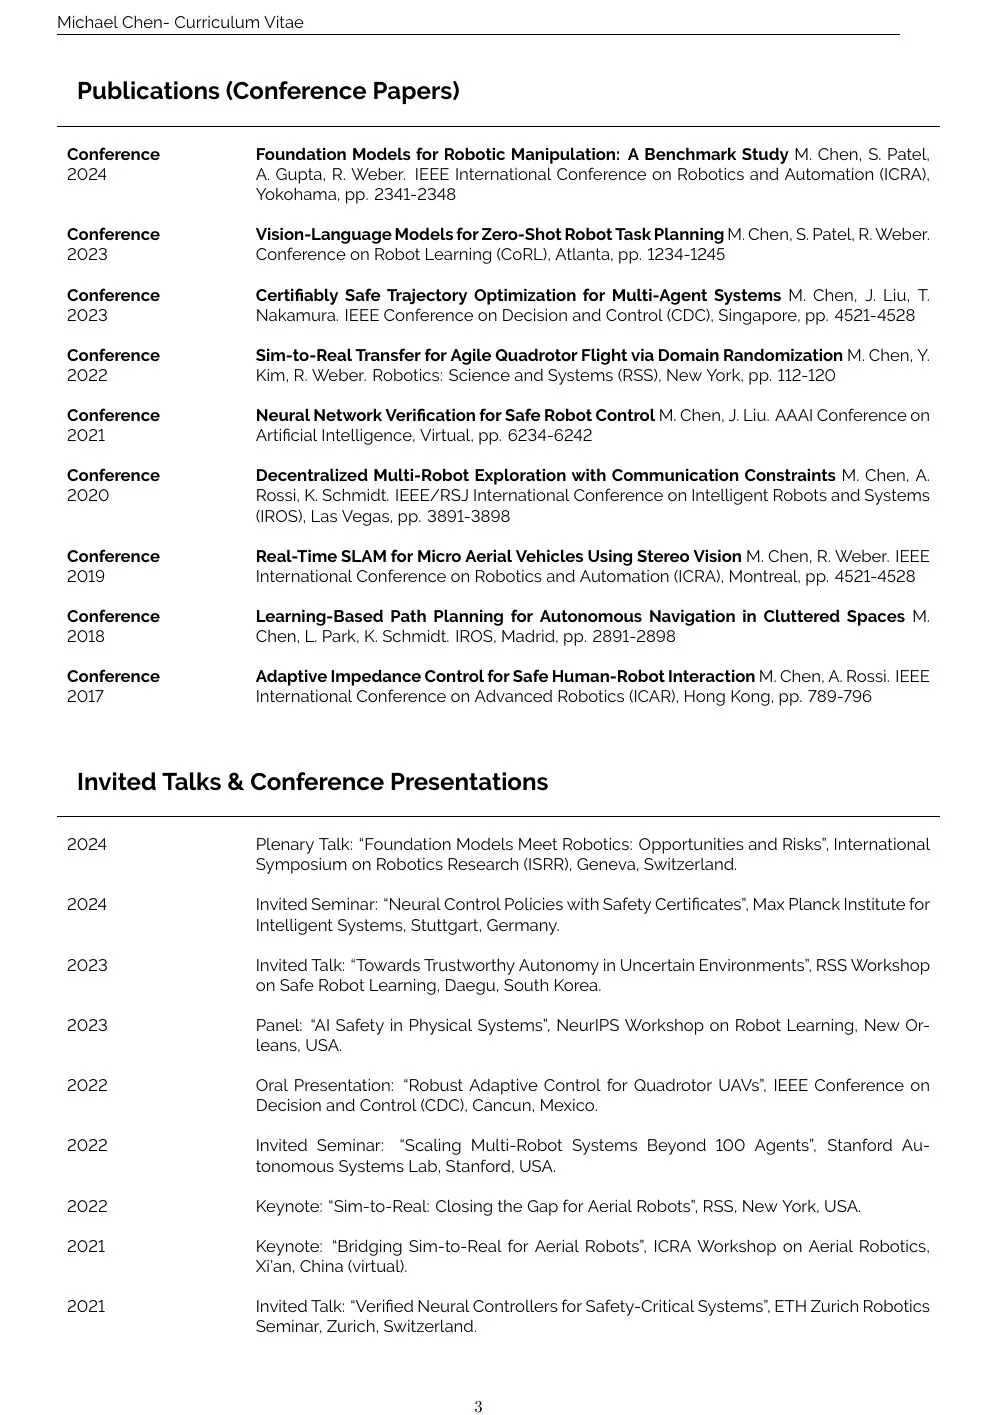
Foundation Models for Robotic Manipulation: A Benchmark Study · IEEE International Conference on Robotics and Automation (ICRA)
2024
M. Chen, S. Patel, A. Gupta, R. Weber. IEEE International Conference on Robotics and Automation (ICRA), Yokohama, pp. 2341-2348
Vision-Language Models for Zero-Shot Robot Task Planning · Conference on Robot Learning (CoRL)
2023
M. Chen, S. Patel, R. Weber. Conference on Robot Learning (CoRL), Atlanta, pp. 1234-1245
Certifiably Safe Trajectory Optimization for Multi-Agent Systems · IEEE Conference on Decision and Control (CDC)
2023
M. Chen, J. Liu, T. Nakamura. IEEE Conference on Decision and Control (CDC), Singapore, pp. 4521-4528
Sim-to-Real Transfer for Agile Quadrotor Flight via Domain Randomization · Robotics: Science and Systems (RSS)
2022
M. Chen, Y. Kim, R. Weber. Robotics: Science and Systems (RSS), New York, pp. 112-120
Neural Network Verification for Safe Robot Control · AAAI Conference on Artificial Intelligence
2021
M. Chen, J. Liu. AAAI Conference on Artificial Intelligence, Virtual, pp. 6234-6242
Decentralized Multi-Robot Exploration with Communication Constraints · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
2020
M. Chen, A. Rossi, K. Schmidt. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, pp. 3891-3898
Real-Time SLAM for Micro Aerial Vehicles Using Stereo Vision · IEEE International Conference on Robotics and Automation (ICRA)
2019
M. Chen, R. Weber. IEEE International Conference on Robotics and Automation (ICRA), Montreal, pp. 4521-4528
Learning-Based Path Planning for Autonomous Navigation in Cluttered Spaces · IROS
2018
M. Chen, L. Park, K. Schmidt. IROS, Madrid, pp. 2891-2898
Adaptive Impedance Control for Safe Human-Robot Interaction · IEEE International Conference on Advanced Robotics (ICAR)
2017
M. Chen, A. Rossi. IEEE International Conference on Advanced Robotics (ICAR), Hong Kong, pp. 789-796
Languages
English
Mandarin
Custom sections
Invited Talks & Conference Presentations
- 2024: Plenary Talk: “Foundation Models Meet Robotics: Opportunities and Risks”, International Symposium on Robotics Research (ISRR), Geneva, Switzerland.
- 2024: Invited Seminar: “Neural Control Policies with Safety Certificates”, Max Planck Institute for Intelligent Systems, Stuttgart, Germany.
- 2023: Invited Talk: “Towards Trustworthy Autonomy in Uncertain Environments”, RSS Workshop on Safe Robot Learning, Daegu, South Korea.
- 2023: Panel: “AI Safety in Physical Systems”, NeurIPS Workshop on Robot Learning, New Orleans, USA.
- 2022: Oral Presentation: “Robust Adaptive Control for Quadrotor UAVs”, IEEE Conference on Decision and Control (CDC), Cancun, Mexico.
- 2022: Invited Seminar: “Scaling Multi-Robot Systems Beyond 100 Agents”, Stanford Autonomous Systems Lab, Stanford, USA.
- 2022: Keynote: “Sim-to-Real: Closing the Gap for Aerial Robots”, RSS, New York, USA.
- 2021: Keynote: “Bridging Sim-to-Real for Aerial Robots”, ICRA Workshop on Aerial Robotics, Xi’an, China (virtual).
- 2021: Invited Talk: “Verified Neural Controllers for Safety-Critical Systems”, ETH Zurich Robotics Seminar, Zurich, Switzerland.
- 2020: Oral: “Decentralized Exploration Under Communication Constraints”, IROS, Las Vegas, USA (virtual).
- 2019: Poster: “Real-Time SLAM for MAVs”, Robotics: Science and Systems (RSS), Freiburg, Germany.
- 2018: Oral: “Learning-Based Path Planning”, IROS, Madrid, Spain.
- 2017: Workshop Talk: “From Factory Floors to Open Skies”, IEEE CASE Workshop on Industrial Robotics, Xi’an, China.
Grants and Funding
- 2024: ONR Young Investigator Program (PI), Office of Naval Research - “Autonomous Maritime Inspection with Heterogeneous Robot Teams” - $500,000 over 3 years. Arlington, USA
- 2023: NSF CAREER Award (Co-PI), National Science Foundation - “Resilient Multi-Agent Systems for Infrastructure Inspection” - $450,000 over 3 years. Cambridge, USA
- 2022: Amazon Research Award, Amazon Science - “Safe Robot Learning for Warehouse Automation” - $80,000 (1 year, unrestricted). Seattle, USA
- 2021: DARPA Young Faculty Award, Defense Advanced Research Projects Agency - “Adaptive Control Under Adversarial Conditions” - $200,000 over 2 years. Arlington, USA
- 2020: MIT Lincoln Laboratory Internal R&D, MIT Lincoln Laboratory - “Autonomous Drone Swarms for Search and Rescue” - $350,000 over 2 years. Cambridge, USA
- 2017: ETH Research Grant, ETH Zurich Foundation - Doctoral research funding for autonomous navigation in GPS-denied environments - CHF 120,000. Zurich, Switzerland
Professional Service
- Editorial: Associate Editor, IEEE Robotics and Automation Letters (RA-L), 2023-present
- Editorial: Guest Editor, Special Issue on “Safe Learning for Robotics”, Autonomous Robots, 2024
- Reviewer: IEEE Transactions on Robotics (T-RO)
- Reviewer: IEEE Transactions on Automatic Control (TAC)
- Reviewer: Automatica
- Reviewer: International Journal of Robotics Research (IJRR)
- Reviewer: Journal of Field Robotics
- Reviewer: Science Robotics
- Program Committee: ICRA 2022, 2023, 2024 (Area Chair 2024)
- Program Committee: IROS 2021, 2022, 2023, 2024
- Program Committee: CoRL 2023, 2024
- Program Committee: RSS 2024 (Workshop Co-Chair)
- Panel Service: NSF Review Panel, Robotics and AI program, 2023
- Panel Service: DARPA Proposer’s Day reviewer, Autonomous Systems, 2022
Supervision & Mentoring
- PhD Students: Jing Liu (co-supervised with Prof. R. Weber), "Verified Neural Controllers for Safety-Critical Robotics", expected 2025
- PhD Students: Yuna Kim (co-supervised with Prof. T. Nakamura), "Energy-Optimal Planning for Long-Range UAV Missions", expected 2026
- Master’s Theses: S. Patel (2023): “Vision-Language Grounding for Robotic Manipulation” - now PhD student at CMU
- Master’s Theses: A. Gupta (2023): “Sim-to-Real for Dexterous Grasping” - now at Boston Dynamics
- Master’s Theses: K. Novak (2022): “Communication-Efficient Multi-Robot SLAM” - now at Skydio
- Master’s Theses: M. Bharadwaj (2021): “Cooperative Object Transport with Quadrotors” - now PhD at Stanford
- Master’s Theses: L. Torres (2021): “FPGA-Accelerated MPC for Agile Flight” - now at NVIDIA
- Undergraduate Researchers: 3 MIT UROP students (2021-present)
- Undergraduate Researchers: 2 ETH semester project students (2018-2019)
Teaching Experience
- 2021-present: Guest Lecturer, Embedded Systems (6.S079), MIT, Department of EECS, Cambridge, USA. Delivered 8 lectures per semester on real-time operating systems and sensor interfaces for graduate course. Developed new lab module on ROS2-based drone programming adopted permanently into curriculum.
- 2023: Short Course Instructor, IEEE International Conference on Robotics and Automation, London, UK. Co-taught full-day tutorial “Safe Learning for Robot Control” with Prof. R. Weber. 120 attendees.
- 2016-2019: Teaching Assistant, Control Systems, ETH Zurich, Zurich, Switzerland. Led weekly tutorial sessions for 60+ students in undergraduate control theory. Designed lab exercises for PID controller tuning on physical plants. Received teaching evaluation score of 5.6/6.0.
- 2018: Workshop Instructor, IEEE Robotics and Automation Society, Munich, Germany. Taught a 2-day hands-on workshop on ROS-based robot programming for 30 industry professionals.
Media & Public Engagement
- 2024: Featured in MIT News: “Drone swarms that think for themselves”
- 2023: Interview, IEEE Spectrum: “The Next Frontier in Multi-Robot Coordination”
- 2022: Panelist, World Economic Forum, “AI and the Future of Autonomous Systems” (virtual)
- 2021: Science communicator, MIT Open Learning: recorded 4-part video series on “Robotics for Everyone” (45K views)
← Harder: Senior Full-Stack EngineerEasier: Graphic Designer →All published resumes


